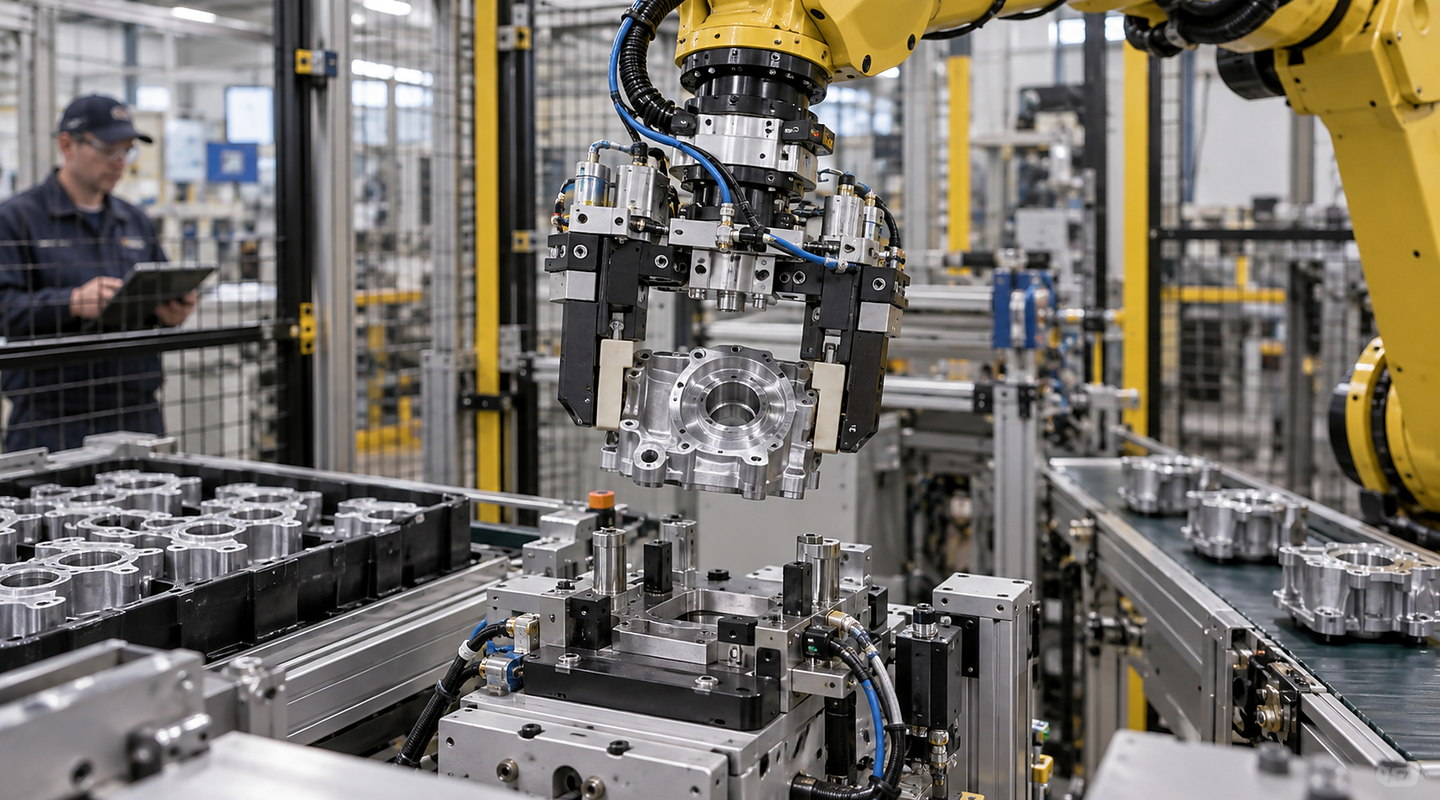
Automatic Robot Tool Changing Systems Selection Guide
Compare automatic tool exchange with fixed or manually changed tooling. Use the same application conditions and record what each proposal includes, excludes or still needs to prove.
Check loads, services, rack access, coupling confirmation and interrupted changes. Compare full changeover time, operator access, service reconnection and repeatable setup.
For repeatable production using automatic robot tool-changing systems, a short trial that reproduces the difficult condition is often more useful than a long list of nominal specifications.
Compare options in the conditions where they must work — Automatic Robot Tool Changing Systems
Plan automatic robot tool changing systems around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. A useful shortlist should show how every option copes with part, product and process variation for automatic robot tool-changing systems and operator access, recovery and changeover.
Discuss your application
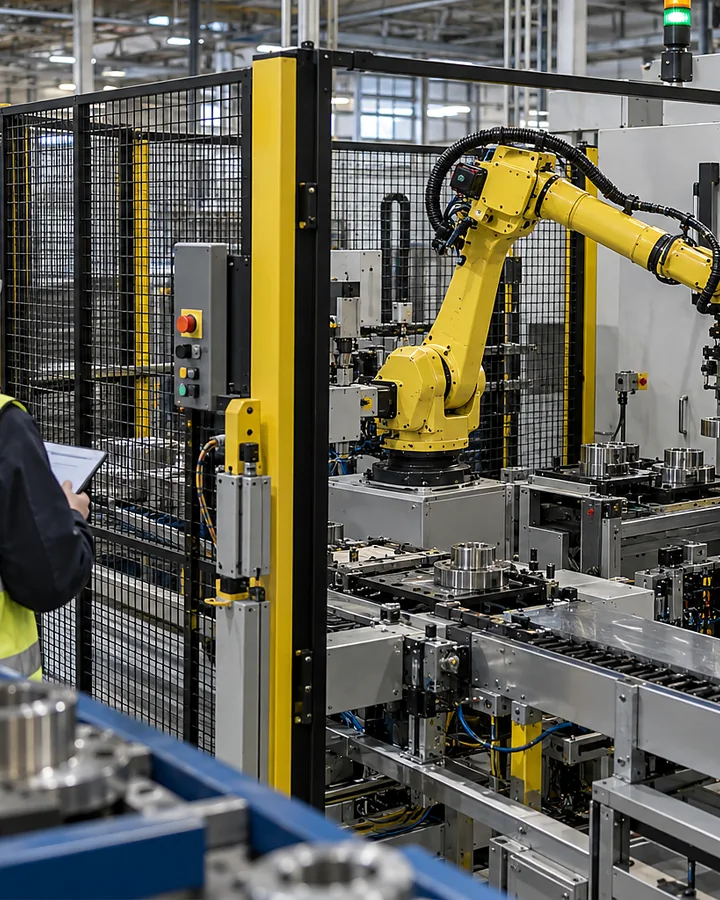
Ask every supplier the same questions
| Decision to resolve | Evidence to compare |
|---|---|
| What loads act through each tool? | Tool mass, centre of gravity and process loads. |
| Which services cross the coupling? | Service schedule for every tool. |
| Where will each tool be stored? | Rack layout and full approach envelope. |
| How is a successful connection confirmed? | Coupled-state, tool-ID and service-ready signals. |
| What is the complete change cycle? | Complete exchange-time record. |
| What happens when an exchange is interrupted? | Interrupted-exchange and controlled-recovery tests. |
Include simpler approaches to automatic robot tool-changing systems in your shortlist
| Route to assess | When it belongs in the comparison | Deciding check |
|---|---|---|
| Automatic tool exchange | The production schedule requires tool changes within the controlled robot sequence. | Check loads, services, rack access, coupling confirmation and interrupted changes. |
| Fixed or manually changed tooling | The task or change frequency supports a simpler assessed tooling arrangement. | Compare full changeover time, operator access, service reconnection and repeatable setup. |
Pause before choosing when…
- Only perfect or hand-selected examples of repeatable production using automatic robot tool-changing systems are available.
- No one has defined how run-off criteria and production evidence will be evaluated.
- The normal range for part, product and process variation for automatic robot tool-changing systems is described only as “usually fine” but has not been bounded.
- Your operator, cleaning, maintenance or recovery access has not been considered.
- Quoted performance depends on another machine or data source that is not included.