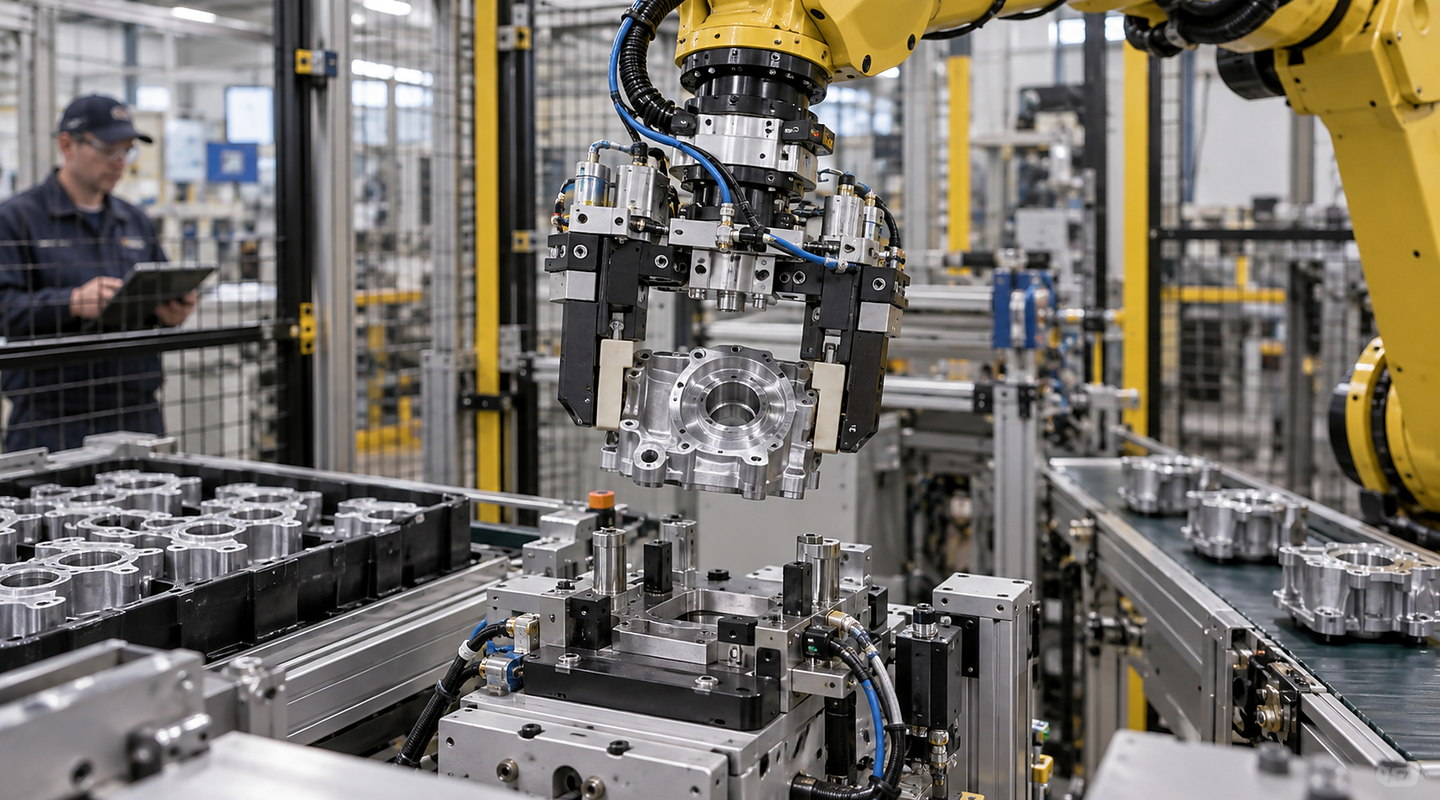
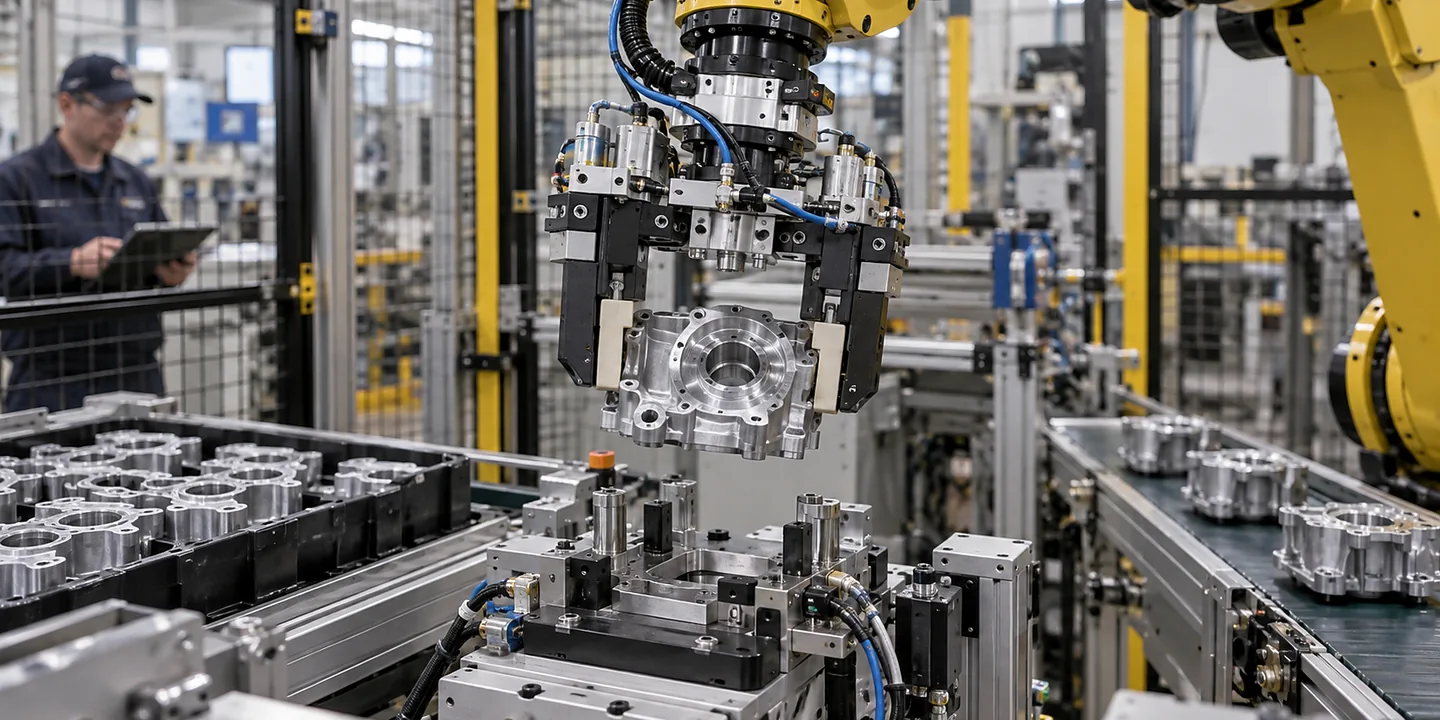
Yellow robot arm with a gripper holding a metal component above a fixture.
Industrial automation and robotics

Automatic Robot Tool Changing Systems

Automatic robot tool changers connect the robot to different end-of-arm tools during a production sequence. Select the changer using tool loads and moments, service connections and docking conditions. Include the tool rack, control confirmation and safe recovery within the complete cell specification.

Speak directly with Oxford Industrial Automation about automatic robot tool-changing systems.

Quick answer

What should we specify for an automatic robot tool changer?

List each tool’s mass, geometry, services and process loads, including hoses and cables. Define storage positions and the confirmation required after coupling. Review the changer, robot and complete tool arrangement together, then trial connection, release and fault recovery with the intended tooling and operating conditions.

Yellow robot arm with a gripper holding a metal component above a fixture.
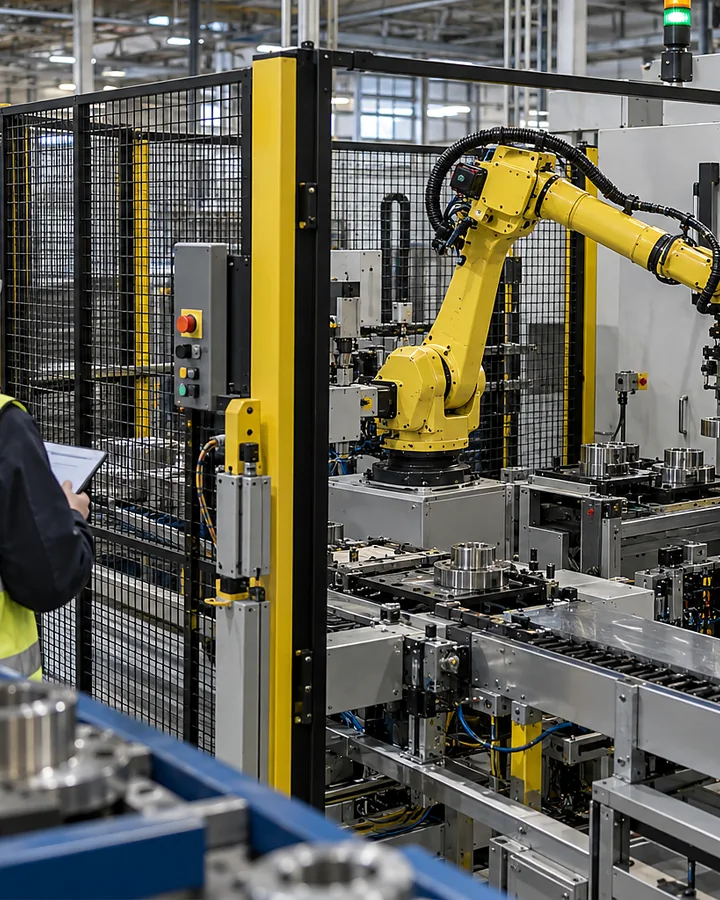
Yellow robot arm and metal tooling beside component fixtures.
Application decisions

Assess the complete tool-changing arrangement

Tool mass alone does not describe the load on a changer. The tool geometry, process force and service connections also need review.

Decision 1

What loads act through each tool?

List tool and carried-part mass, centre of gravity and the forces from the process. Include adapters, cables and hoses. Ask for the proposed changer and robot combination to be checked against the applicable load and moment limits.

Decision 2

Which services cross the coupling?

List air, vacuum, power, signals and other connections separately for every tool. Define pressure, flow or electrical needs through the appropriate engineering review. Confirm connector compatibility and what happens to each service while a tool is parked or exchanged.

Decision 3

Where will each tool be stored?

Provide rack positions, tool envelopes, approach directions and service clearance. Check access for the whole robot movement, including the least compact tool. Docking needs repeatable support and a controlled approach, not merely an empty space beside the cell.

Decision 4

How is a successful connection confirmed?

Define tool identity, coupled state and any service-ready signals needed before motion or processing resumes. Distinguish a command to lock from confirmation that the connection has succeeded. Include how an unexpected or unavailable tool is handled.

Decision 5

What is the complete change cycle?

Count travel to the rack, deposit, release, pickup, confirmation and return to work. Compare the change frequency with the production schedule. A short coupling movement does not describe the time the cell spends away from its productive task.

Decision 6

What happens when an exchange is interrupted?

Review loss of services, failed coupling, incorrect tool identity and recovery from an uncertain position. Assign the appropriate safeguards through the cell assessment. Record approved intervention and inspection methods so recovery does not depend on improvisation.

Applications

Two useful starting points for automatic robot tool changing systems

The right choice changes with part, product and process variation for automatic robot tool-changing systems, arrival pattern and presentation, your line layout and required results.

Practical project evidence

What to record in the application trial

Use the heaviest and most offset approved tools as well as the most difficult service connection. Check approach, docking, release, pickup and confirmation through the intended production sequence. Record faults and recovery results with the tool identity and rack position. Final load suitability requires the manufacturer’s engineering limits for the actual configuration.

Use the selection guide to compare the scope, then send the specification checklist with your application enquiry.

Important limits

Know what needs a separate check

Your final solution for automatic robot tool-changing systems must reflect the law, current standards and site-specific risks that apply to your installation.

Treat docking, locking and tool readiness as separate confirmations

An automatic tool change is complete only when the intended tool is correctly coupled and the cell has the confirmations required for the next operation. A robot reaching the stored docking position is only one event in that sequence.

Define a stable storage position

Include the tool plate, end effector, service modules, cables and hoses in the storage arrangement. Review support and alignment against the chosen changer manufacturer requirements. ATI’s tool-stand guidance highlights the need for a repeatable, stable pickup and drop-off position and support for the complete tool arrangement.

Separate the command from the confirmed state

Identify the signals that establish coupling, release, tool identity and any required service readiness. A command to lock is not the same as confirmation that the required state has been achieved. Define the response to conflicting or missing feedback before the production sequence is implemented.

Check services for the intended tool

List the electrical, pneumatic or other connections needed by each tool and the conditions under which they may connect or disconnect. Include cable and hose behaviour through the robot motion. Follow the chosen equipment instructions and assessed safe procedure rather than assuming every tool may be disconnected in the same state.

Plan an incomplete exchange

Resolve what happens if the rack is occupied, a tool is absent or a change is interrupted. Preserve a clear tool identity and safe recovery route. Keep the approved tool, rack and robot configuration together so a future end-effector change does not silently alter the established exchange conditions.

Review robot tool-changing systems — explore the existing guidance

Further reading: ATI tool-changer and stand guidance.